Engineering & Inventions · Machines & robotics
How feedback keeps a machine on target
Cruise control holds your speed on a hill it can't see. Follow the loop that does it, from measuring the gap to correcting it, and find out why correcting faster can cause new problems.
What you will learn
- Explain what the target, measurement, error and action each do in a feedback loop.
- Tell feedback control apart from a fixed command when conditions change.
- Explain how proportional control ties the correction to the present error.
- Explain why accumulated error can help remove a persistent mismatch.
Lesson 1 of 4 · 3 min
How does cruise control notice a hill?
Hold a car's accelerator in one position and drive onto a hill. The car slows down. Your foot hasn't moved, so the command is the same, but the result has changed.
Cruise control never sees the hill. It measures the speed, compares it with the speed you set, and changes what it asks of the engine.
Each part of that loop has a name. The sensor measures the speed. The controller decides what to do about it. The thing being controlled, here the car and its engine, is called the plant.
The number the controller works from is the error, which is the target speed minus the measured speed. A positive error means the car is going slower than the target. A negative error means it's going too fast.
Say you set 80 kilometers per hour and the sensor reads 76. The error is 4 kilometers per hour.
That 4 isn't an instruction. It doesn't say how much harder the engine should work. So the controller needs a rule that turns a speed gap into an engine command.
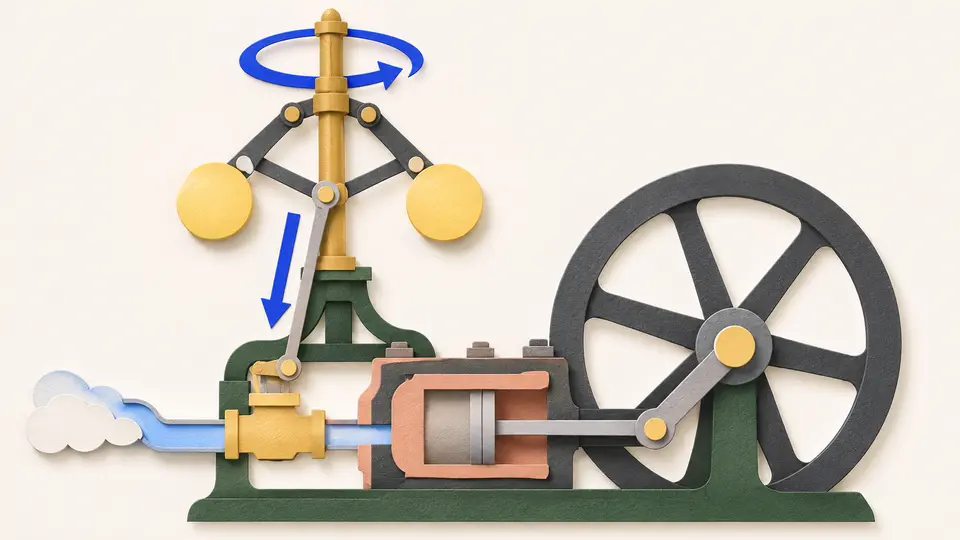
This arrangement is called feedback, because the result of each action comes back into the next decision. More engine effort raises the speed. The new speed gives a new error, and the controller adjusts again.
The loop never stops checking. It doesn't assume a command that was right on the flat is still right on the climb.
A command that ignores its own result is called open-loop. Holding the pedal still is open-loop control. It works on a flat, empty road, where conditions are predictable. A hill or a heavier load exposes it, because the command stays put while the speed drifts.
A human driver closes the loop by watching the speedometer, and some do it badly. Ralph Teetor, a blind engineer, rode with a lawyer who slowed down when he talked and sped up when he listened. By his family's account, that lurching drove Teetor to invent cruise control, patented in 1950.
A speed controller never works out why the car slowed. A hill, a heavier load and a rougher road all look the same to it, because it sees only the speed error. So one simple loop copes with causes its designer never listed.
The loop has limits. It's only as good as its speed measurement, and it can't ask the engine for more power than the engine has.
Try to recallWhy can a feedback speed controller adjust to a changed load when a fixed engine command can't?
Feedback measures the resulting speed, compares it with the target and changes the command when an error appears. The fixed command takes no notice of the changed result.
Lessons in this topic
How does cruise control notice a hill?
Cruise control never sees the hill. Learn the loop that holds your speed anyway, by measuring, comparing with a target and correcting the engine command.
Why cruise control needs a memory
A controller that reacts only to the present speed gap always settles short of its target. See why, and how adding up past error closes the gap.
Why the fastest controller isn't always the best
Learn the three measures engineers use to judge a controller's response, and why a result that looks perfect in a simulation can be impossible for the real machine.
How a controller brakes before it overshoots
The derivative term reacts to how fast the gap is closing, which cuts overshoot. See what it changes, and why the three gains have to be tuned together.
Three quick stories from this topic
The gap that has to stay
A cruise controller that reacts only to the current speed gap never reaches its target
Holding speed takes a steady push from the engine, and this kind of controller pushes only while a gap exists. Zero gap would mean zero push. In one university tutorial's car model, asking for 10 meters per second gets about 6.7.
A bigger gain only shrinks the gap
Turning the controller's gain up to 10,000 in the same model pushed the error to near zero. Proportional control can reduce a steady error but never eliminate it.
Memory closes it
Integral control adds up the error over time. Its running total keeps pushing even at zero error, so the car can sit on its target.
The blind inventor of cruise control
Cruise control was invented by Ralph Teetor, an engineer blind since early childhood
The idea came while he rode with his patent attorney, who sped up and slowed down as the conversation went. Teetor built a device to hold a car's speed steady, patented it in 1950, and Chrysler first sold it in 1958.
A feedback loop that doesn't get distracted
A driver holds a speed by watching it and correcting. Teetor's device did the same job without the lapses, keeping the car at the speed the driver had selected.
The name came later
Teetor's company called it the Speedostat and Chrysler sold it as Auto-Pilot. Cadillac's name for it, Cruise Control, is the one that stuck.
Too fast to be real
One simulated cruise controller took a car to 36 km/h in under half a second
On paper it was the best result yet, with almost no error. But the model never capped the engine's force, so the controller got whatever it asked for. The tutorial's authors called the response unrealistic and chose a gentler setting.
Every command hits a ceiling
The part that carries out a command has a maximum output. A controller that asks for more gets the maximum and nothing extra.
Judge the machine too
A fast curve counts only if the hardware can produce it. Check the commands a design calls for against what the engine or motor can give.
Sources
- PID tutorial, Control Tutorials for MATLAB, University of Siena mirror
- Cruise control: PID controller design, Control Tutorials for MATLAB, University of Siena mirror
- Ralph Teetor, Wikimedia Foundation
- Ralph Teetor, cruise control, National Inventors Hall of Fame